Tech Stack
ROS2
Gazebo
Python
Description
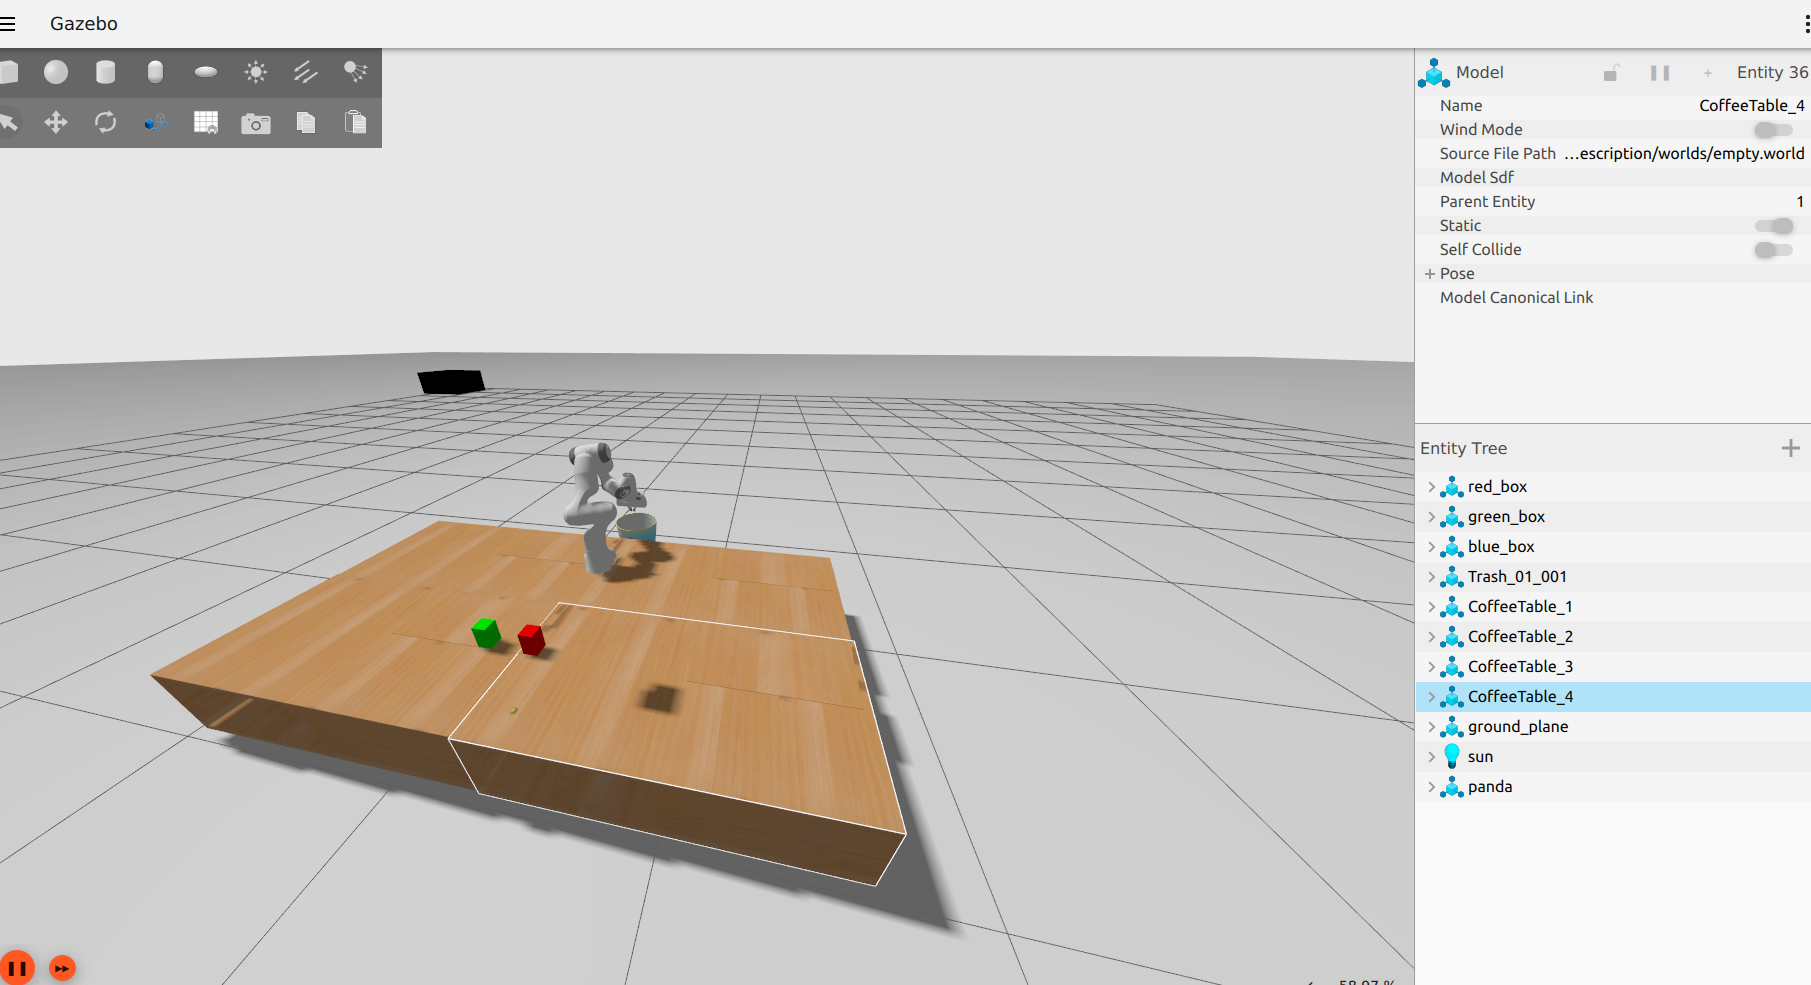
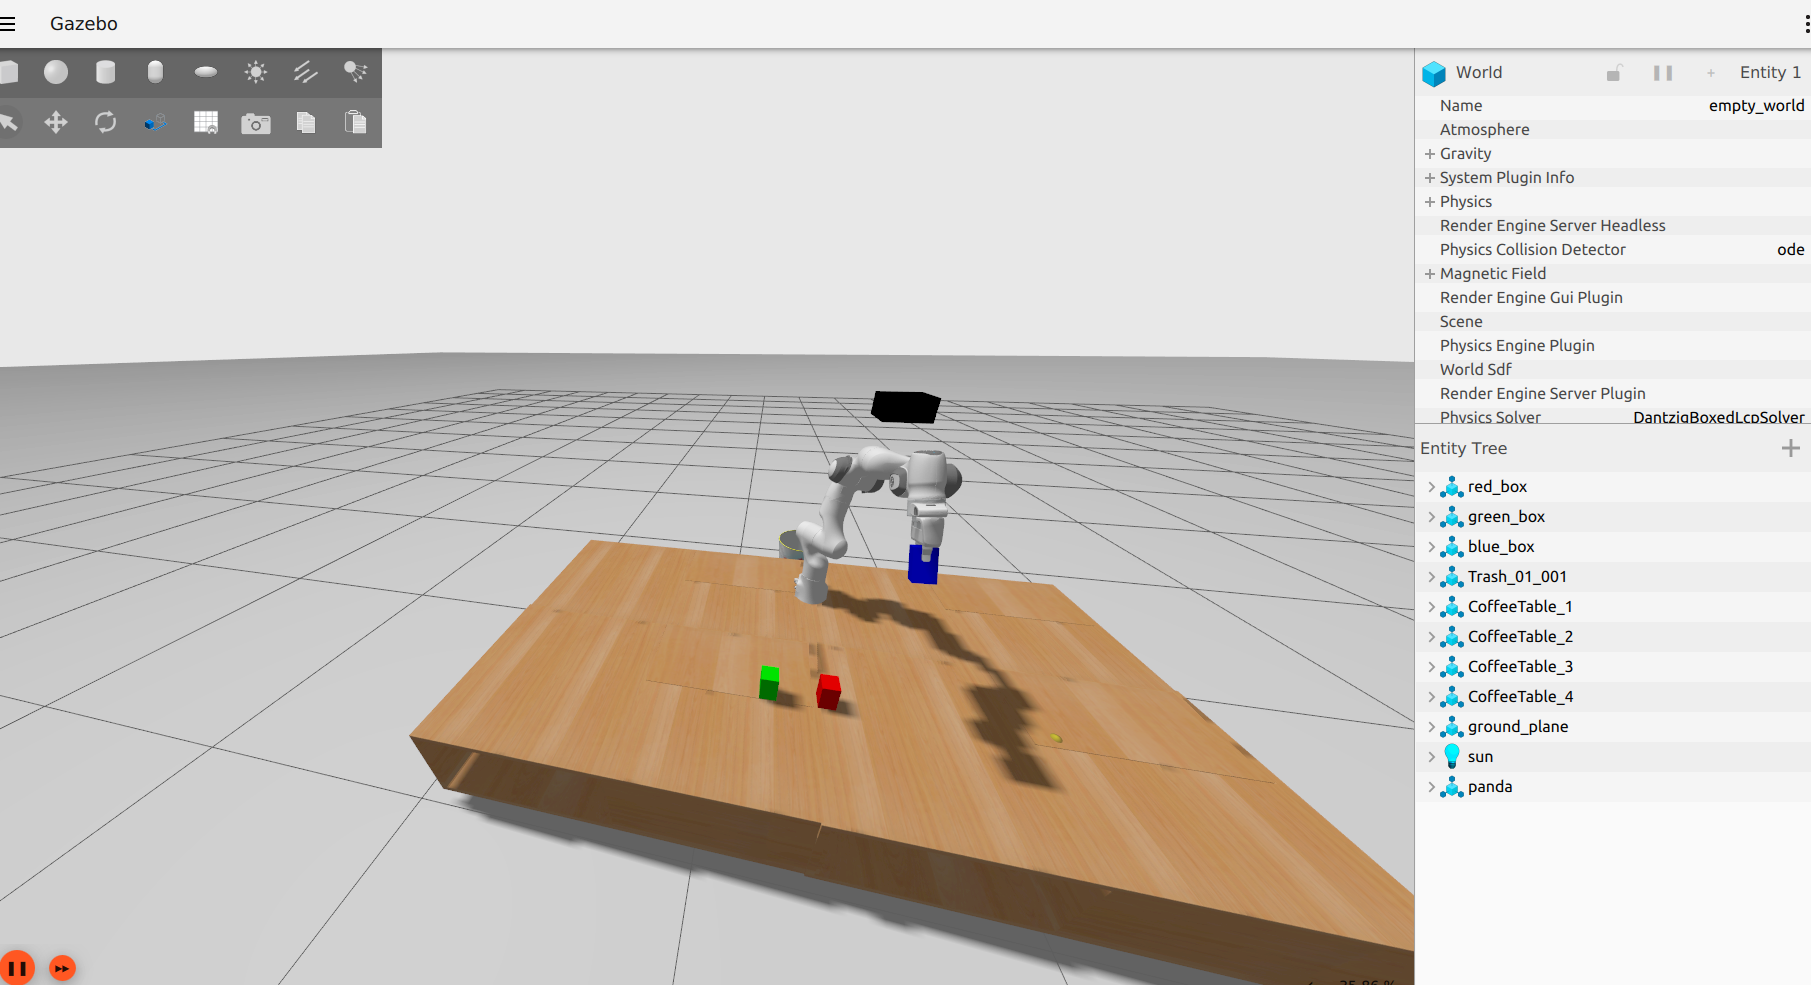
Developed a simulated robotic system using the Franka Panda arm model to autonomously detect, pick, and place objects based on their color.
The system allows users to dynamically assign a target color (Red, Green, or Blue) via terminal commands, prompting the arm to execute the sorting operation.
- Built the simulation environment using ROS2 and Gazebo.
- Implemented computer vision object detection capabilities using OpenCV.
- Managed kinematics and trajectory planning using MoveIt2.
- Wrote the core logic and executable nodes primarily in Python.
Page Info
Simulation & Control
Utilized ROS2, Gazebo, and MoveIt2 to simulate the Franka Panda arm and plan precise pick-and-place trajectories.
Computer Vision
Integrated OpenCV to autonomously detect specific target colors (Red, Blue, or Green) for the arm to sort into designated bins.