Tech Stack
ROS2
Gazebo
Python
Linux
Description
Engineered an autonomous robot capable of navigating elevated surfaces without falling.
The system continuously processes LIDAR scans to calculate the distance to the edge of the table, triggering evasive maneuvers when a threshold is breached.
- Built and configured the robot description and workspace using ROS2.
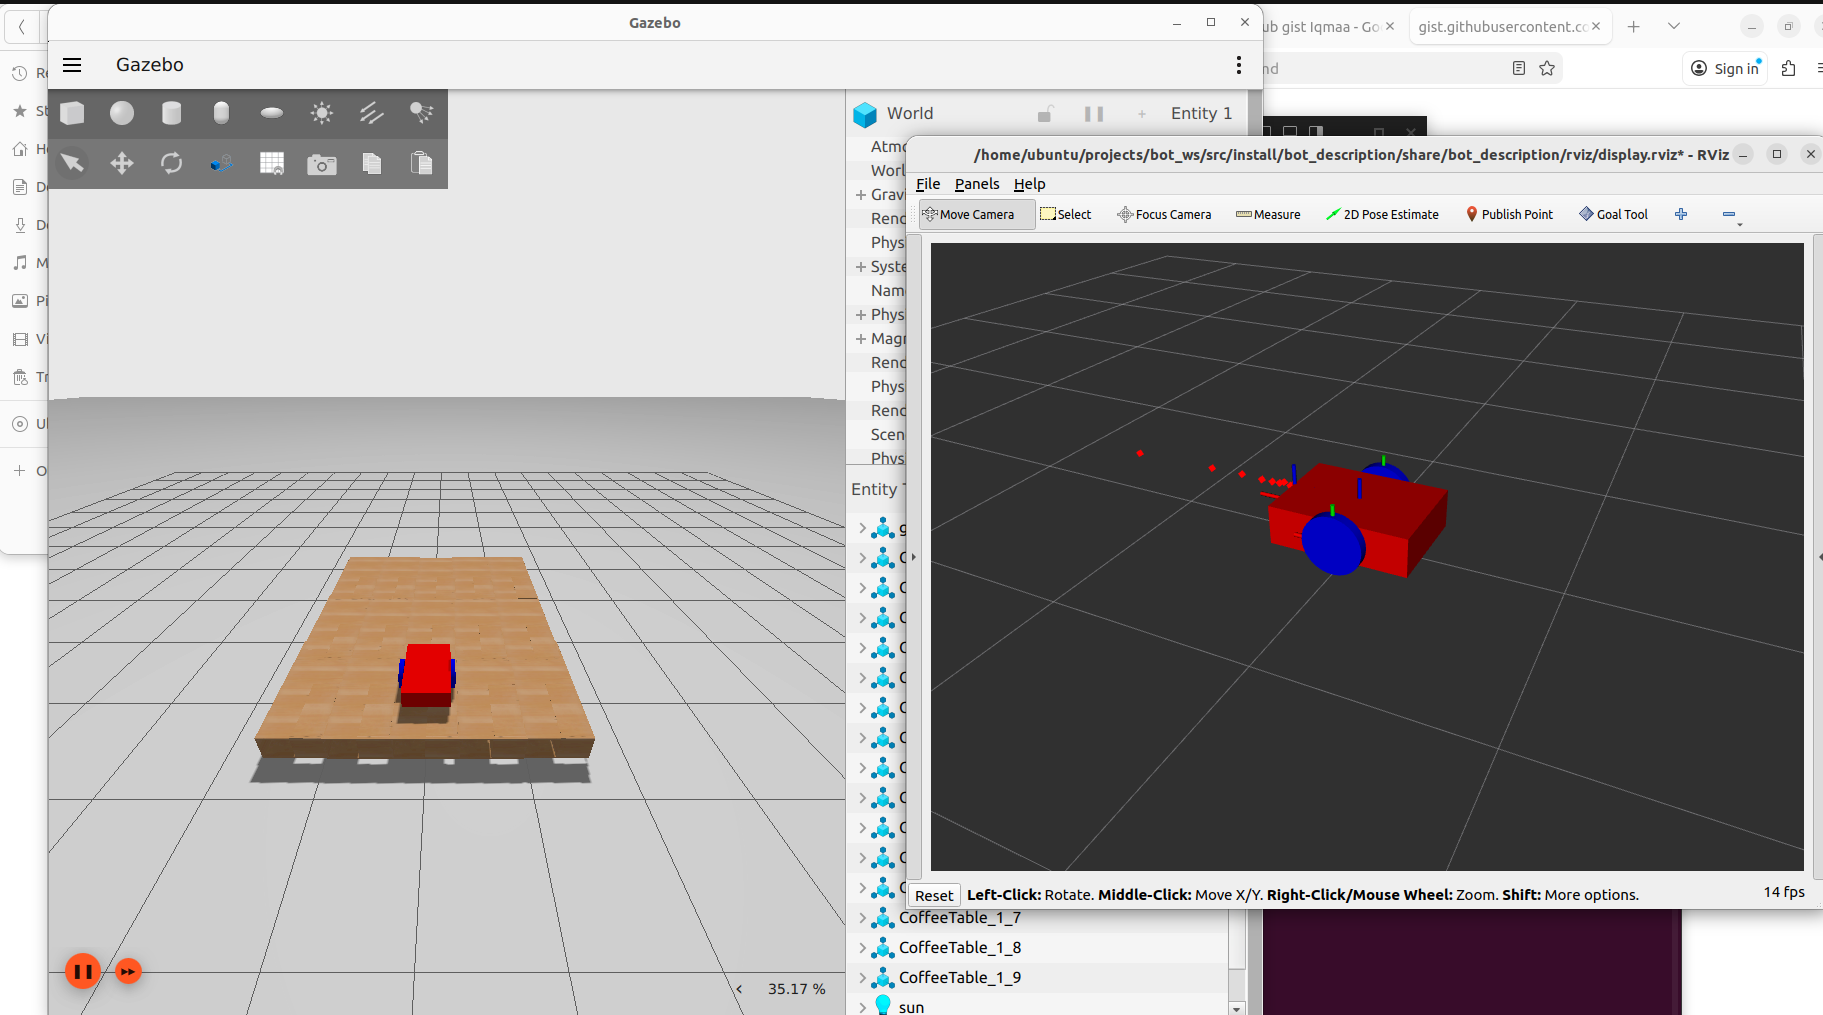
- Simulated the physics and LIDAR sensor data within Gazebo.
- Developed the edge detection and movement logic using Python.
- Visualized sensor data and robot odometry using RViz.
Page Info
Simulation Environment
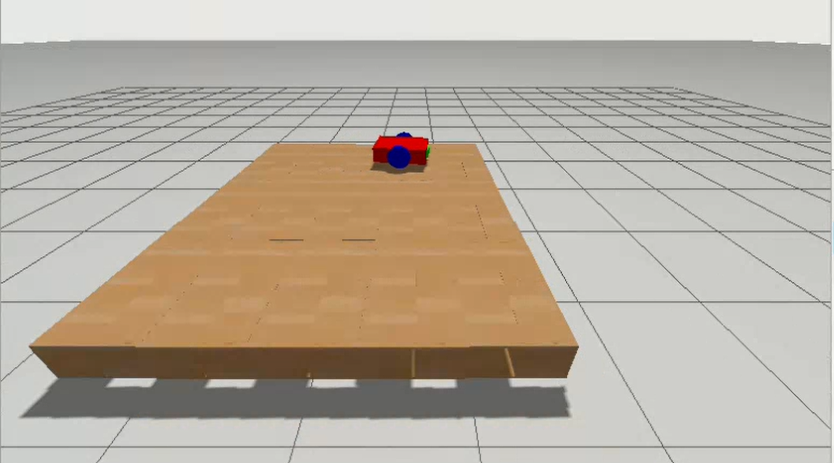
Simulated the robot and a custom elevated table environment using Gazebo, RViz, and ROS2.
Edge Detection & Navigation
Utilized LIDAR sensor data to detect sudden depth changes (edges) and dynamically adjust the robot's velocity to stay on the table safely.